No products in the cart.

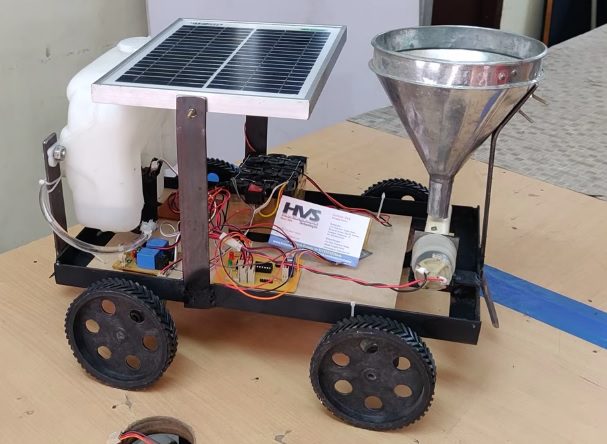
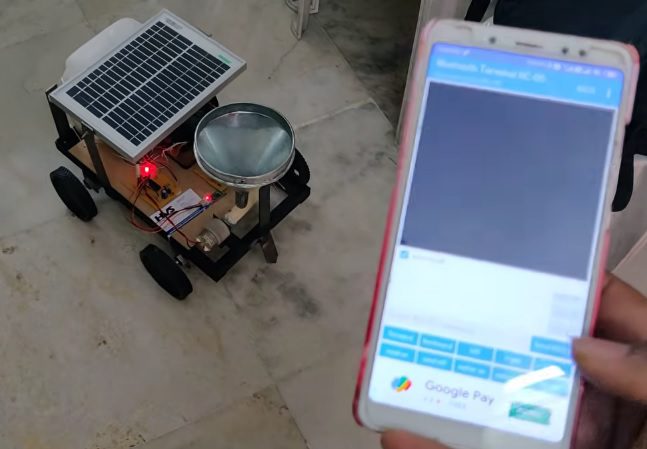
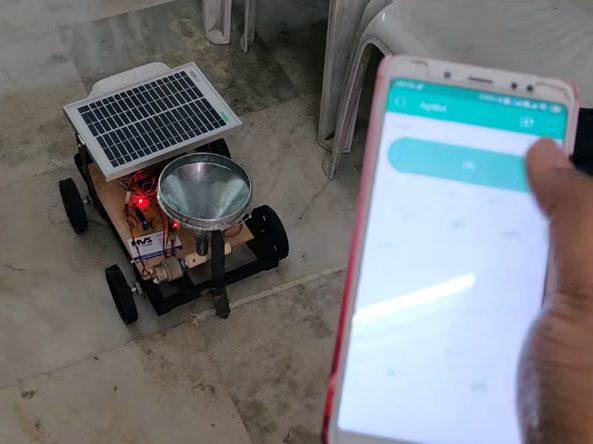
The main aim of this project is to design and develop a solar-powered multipurpose agriculture robot capable of performing major agricultural operations such as ploughing, seed sowing, soil leveling, and water spraying. The robot is designed to reduce manual labour and improve efficiency in agricultural activities. It can be controlled remotely using an Android mobile phone through Bluetooth and the Blynk IoT application.
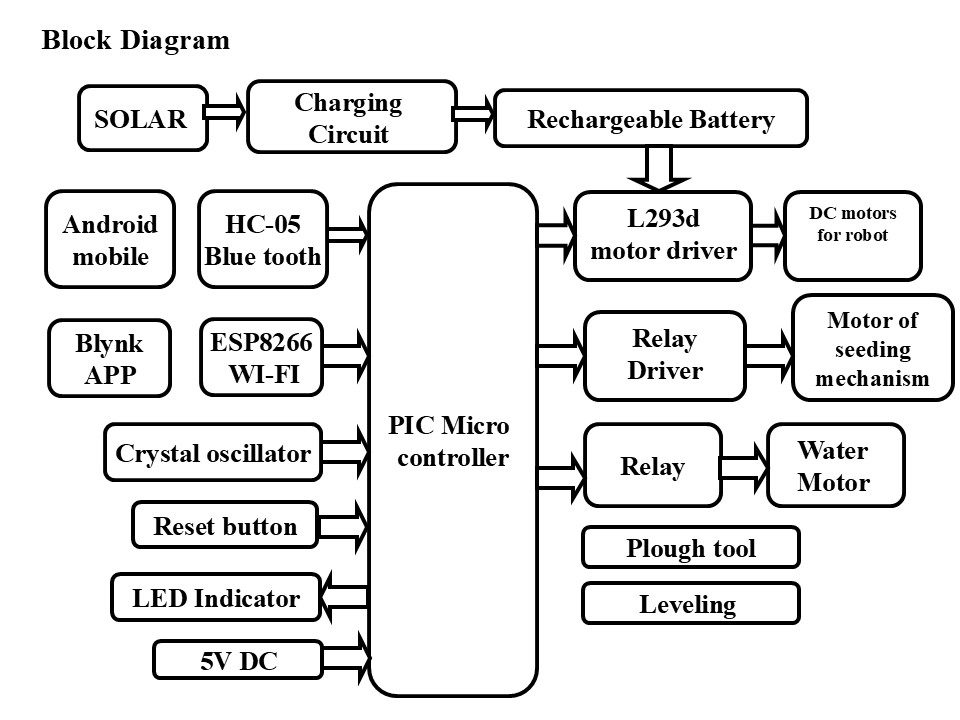
The proposed system uses a PIC microcontroller as the main controlling unit. Two DC motors are interfaced with the microcontroller through a motor driver to control the forward, backward, left, and right movements of the robot. An HC-05 Bluetooth module is used to receive movement and operation commands from the Android mobile phone. The ploughing tool and soil leveling tool are attached to the front and rear sides of the fabricated robot body to perform the respective operations while the robot moves.
A seed-sowing mechanism is implemented using a rotating DC motor connected to a perforated seed-dispensing pipe. A funnel is placed above the rotating pipe to supply seeds. As the pipe rotates, the holes periodically come into the downward position, allowing seeds to fall onto the soil at regular intervals. A water pump is also interfaced with the microcontroller through a relay module. Based on the commands received through Bluetooth, the microcontroller switches the water pump ON or OFF to perform water spraying.
Additionally, a solar panel is integrated into the system to utilize renewable solar energy for supplying power and supporting battery charging. An ESP8266 Wi-Fi module is used to establish IoT connectivity with the Blynk application. Through the Blynk mobile application, the user can remotely monitor and control the supported agricultural operations using an internet connection. The entire system is programmed using Embedded C language to coordinate robot movement, seed sowing, water spraying, and other operations.
Thus, the proposed solar-powered IoT-based multipurpose agriculture robot provides an efficient, cost-effective, and user-friendly solution for automating essential agricultural activities.
Main Features
 video:
- Solar-powered agricultural robot.
- Bluetooth-based manual robot movement control.
- Automatic seed sowing using a rotating perforated pipe.
- Front-side ploughing and rear-side soil leveling.
- Bluetooth and Blynk-based water pump control.
- IoT connectivity using ESP8266 Wi-Fi module.
- Reduced manual labour and improved agricultural efficiency.
- PIC Microcontroller.
- Solar panel.
- Charging circuit.
- Rechargeable Battery.
- DC Motors Along with L293d Driver.
- HC-05 Bluetooth.
- Crystal Oscillator.
- Reset Button.
- Plough Tool.
- Level tool.
- Seed sowing Pipe.
- Water motor.
- ESP8266 WI-FI module.
- PIC-C compiler for Embedded C programming.
- PIC kit 2 programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
- Bluetooth application.
- IOT Blynk application.
 video: