No products in the cart.

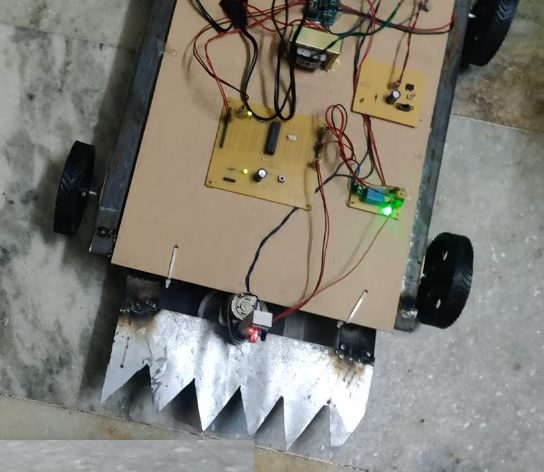
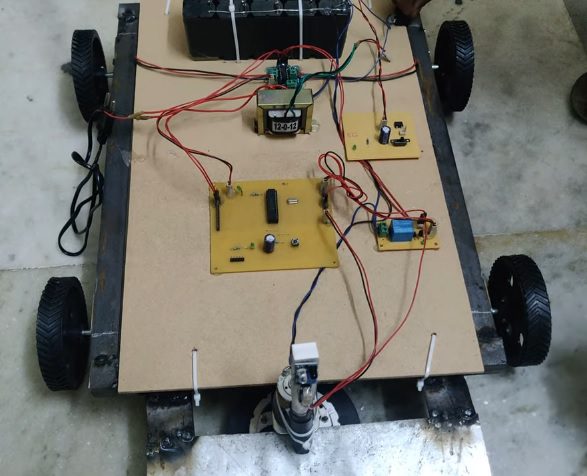
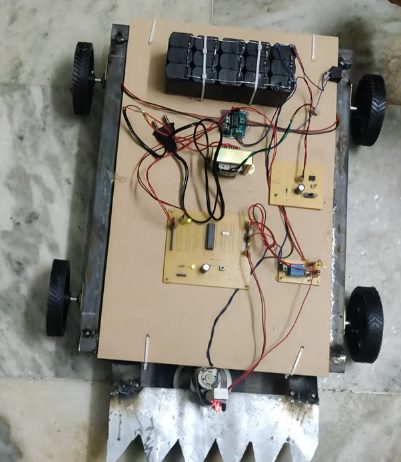
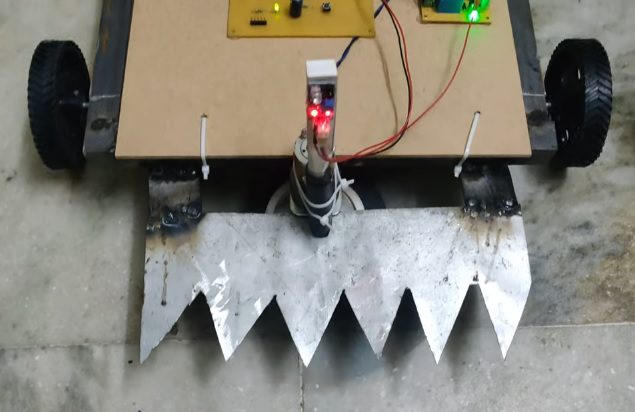
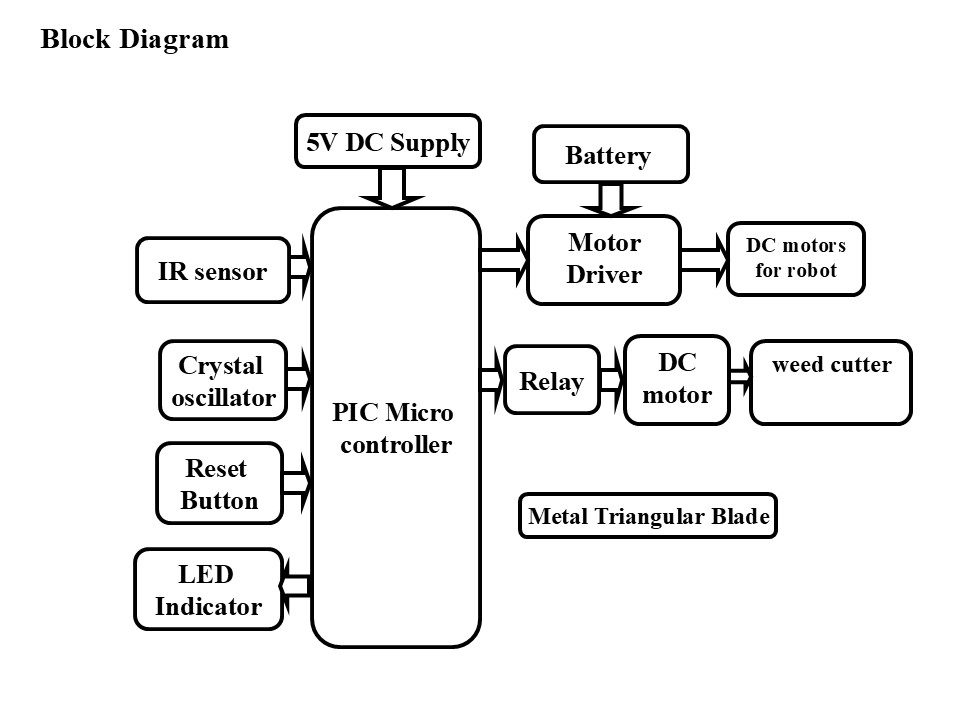
Agriculture plays an important role in the development of the economy, and weed control is one of the major challenges faced by farmers. Unwanted weeds compete with crops for essential nutrients, water, sunlight, and space, resulting in reduced crop growth and productivity. Traditional weed removal methods require considerable human effort, time, and labour. To overcome these challenges, this project proposes an Agriculture Weed Cutter Robot Using Metal Triangular Blades. The proposed system consists of a robotic fabrication body mounted on four wheels for movement, with metal triangular blades attached to the front side to cut unwanted weeds during operation. A PIC microcontroller acts as the main control unit of the system. An IR sensor is used to detect obstacles in front of the robot. Whenever an obstacle is detected, the sensor sends a signal to the PIC microcontroller, which immediately stops the robot to avoid collision. The robot resumes movement when the obstacle is removed. A separate DC motor operates the weed-cutting mechanism through a relay. A 5V DC supply powers the control circuit, while a battery provides the required power for the motors. An LED indicator is provided to indicate the operating status of the system. The robot is designed to reduce manual labour and make weed-cutting operations easier, faster, and more efficient. The front-mounted metal triangular blades help cut unwanted weeds as the robot moves through the agricultural field. Thus, this system provides a simple, low-cost, and efficient approach to agricultural weed management, helping farmers save time and reduce physical effort.
Objectives:
 video:
- To design an agriculture weed cutter robot for removing unwanted weeds in agricultural fields.
- To attach metal triangular cutting blades to the front side of the robot for effective weed cutting.
- To use a PIC microcontroller as the main controlling unit of the system.
- To control the robot movement using DC motors and a motor driver circuit.
- To operate the weed-cutting mechanism using a separate DC motor and relay.
- To detect obstacles using an IR sensor and automatically stop the robot to avoid collisions.
- To provide an LED indicator to display the operating status of the system.
- To reduce manual labour, time and physical effort in agricultural weed removal.
- To develop a simple, low-cost and efficient robotic solution for weed management.
- MS steel frame.
- PIC Microcontroller.
- IR sensor.
- DC motors for Robot movement.
- Relay with Grasscutter Blade.
- Triangle blades.
- Battery power.
- PIC-C compiler for Embedded C programming.
- PIC kit 2 programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
 video: