No products in the cart.

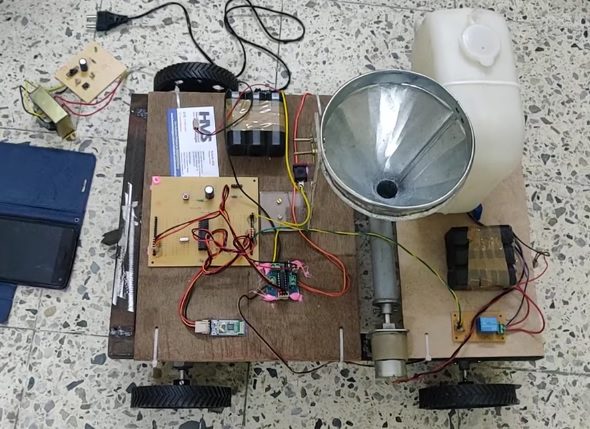
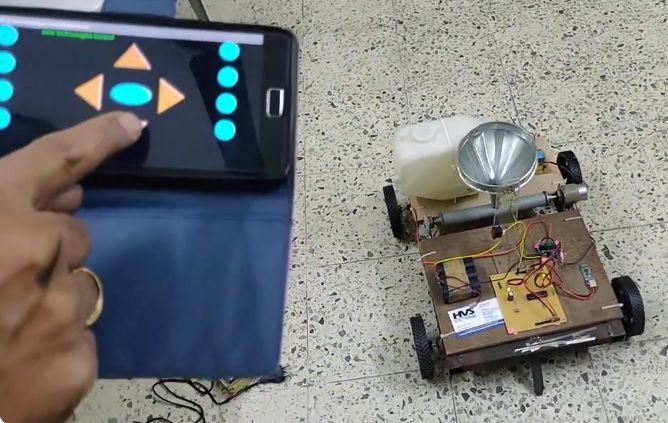
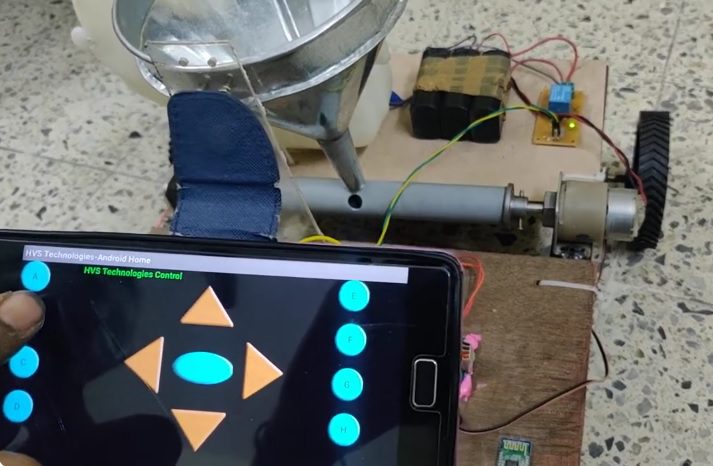
The Multi-Purpose Agriculture Robot is designed to perform various agricultural operations such as ploughing, seed sowing, watering, and land leveling to reduce manual labour and improve farming efficiency. The robot consists of a long metal-fabricated body with a ploughing tool attached to the front side and a leveling tool attached to the backside of the robot.
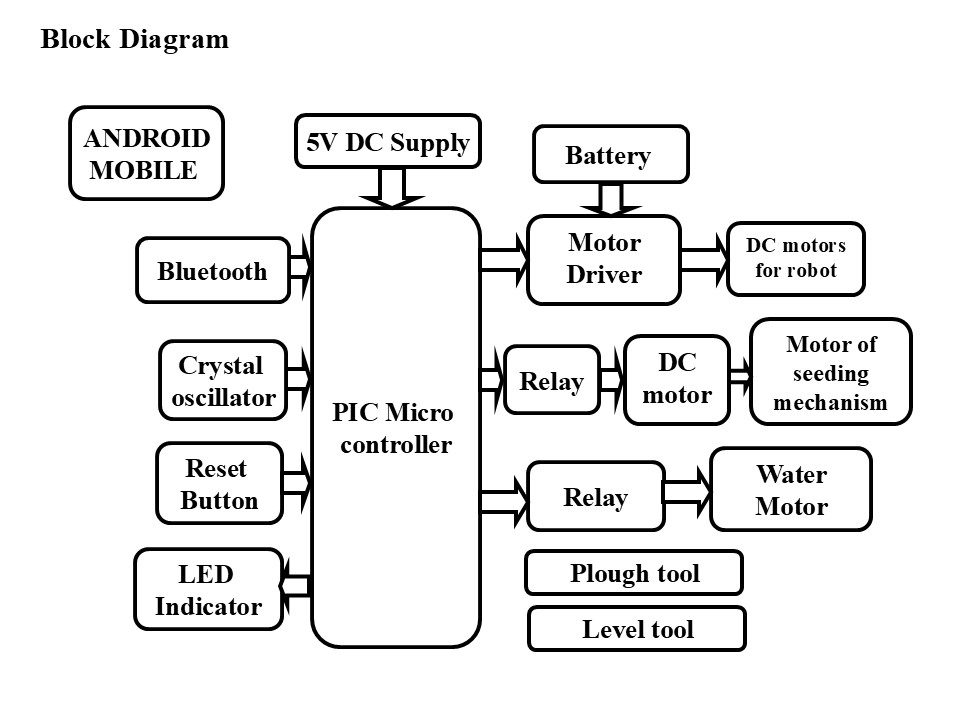
The system uses a PIC microcontroller as the main control unit and a Bluetooth module to receive commands from an Android mobile application. The robot movement is controlled wirelessly through the mobile application in forward, reverse, left, and right directions. The seed-sowing mechanism and water pump can also be independently controlled through the Bluetooth application. When the seed command is given, the microcontroller activates the seed-sowing motor to release seeds into the soil. Similarly, when the watering command is selected, the microcontroller switches ON the water pump to spray water on the agricultural field.
A motor driver is used to control the DC motors responsible for robot movement, while relay circuits are used to operate the seed-sowing motor and water pump. A battery supplies power to the robot, and a 5V DC supply is provided to the control circuit. LED indicators are used to indicate the system operation.
The proposed system provides a simple, low-cost, and user-friendly agricultural solution for small-scale farmers. By integrating multiple farming operations into a single robot with wireless Bluetooth control, it reduces human effort, saves time, and improves the efficiency of agricultural activities.
Objectives:
 video:
- To design and develop a multi-purpose agriculture robot for performing ploughing, seed sowing, watering, and land leveling operations.
- To fabricate a long metal robot body with a ploughing tool at the front and a leveling tool at the backside.
- To control the robot movement in forward, reverse, left, and right directions using an Android mobile application through Bluetooth communication.
- To automate the seed-sowing mechanism using a DC motor controlled through Bluetooth commands.
- To control the water pump wirelessly through the Bluetooth application for watering agricultural fields.
- To use a PIC microcontroller for controlling the robot movement and agricultural operations.
- To reduce manual labour, save time, and improve the efficiency of small-scale farming activities.
- PIC Microcontroller.
- Dc Motors Along with Driver.
- Hc-05 Bluetooth
- Crystal Oscillator.
- Reset Button.
- Rechargeable Battery.
- Plough Tool.
- LEVEL TOOL
- Seed Drilling Pipe.
- Water Sprayer.
- Led Indicators.
- Relay.
- PIC-C compiler for Embedded C programming.
- PIC kit 2 programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
 video: