No products in the cart.

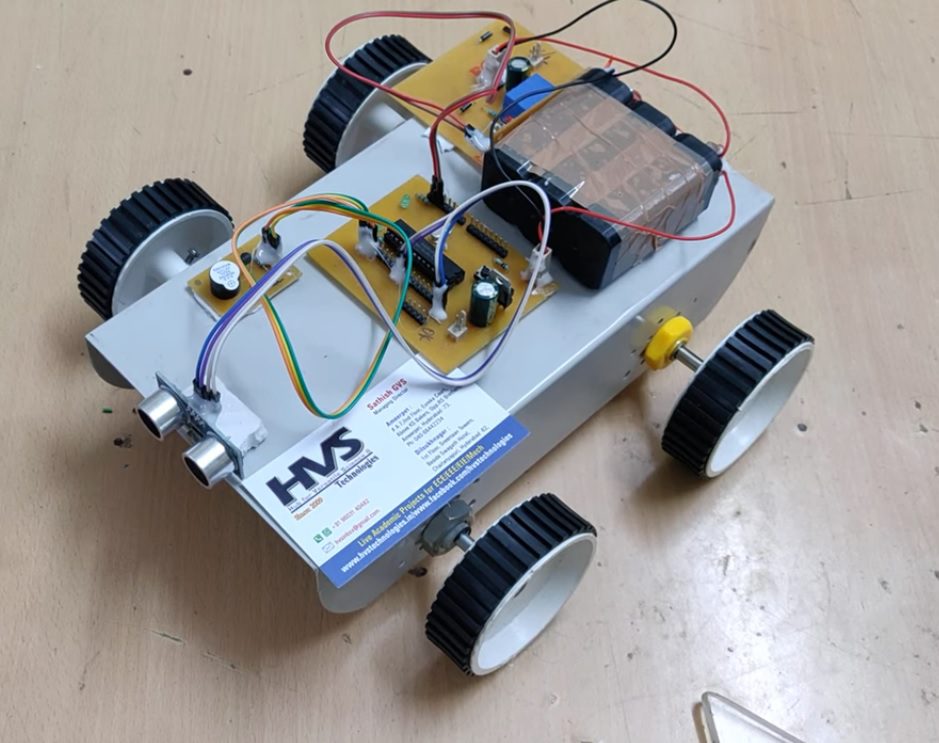
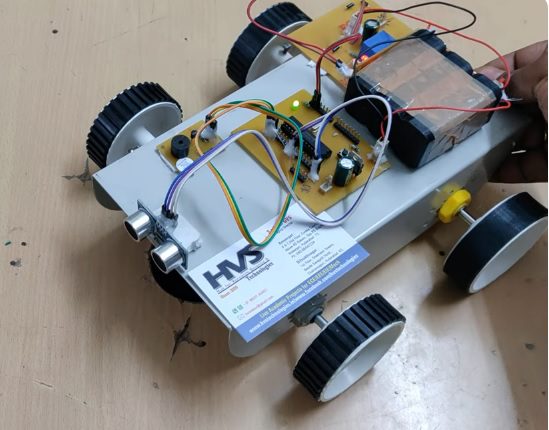
The project aims to design and develop a Bluetooth-controlled wheelchair with an ultrasonic sensor and microcontroller to improve user safety and mobility. The wheelchair is controlled wirelessly through a smartphone application using a Bluetooth module, allowing the user to move the wheelchair in different directions. An ultrasonic sensor is used to detect obstacles and measure the distance between the wheelchair and nearby objects. The measured distance is transmitted to the smartphone application and displayed in real time. If an obstacle is detected within a predefined safety distance, the microcontroller automatically stops the wheelchair to prevent collisions. The main components of the system include a microcontroller, Bluetooth module, ultrasonic sensor, motor driver, DC motors, and a regulated power supply. The microcontroller processes the sensor data and controls the motors according to the user's commands and obstacle conditions. The system is programmed using Embedded C language to provide reliable wireless control, real-time obstacle distance monitoring, and automatic braking, thereby improving wheelchair safety and supporting independent mobility.
Features:
 video:
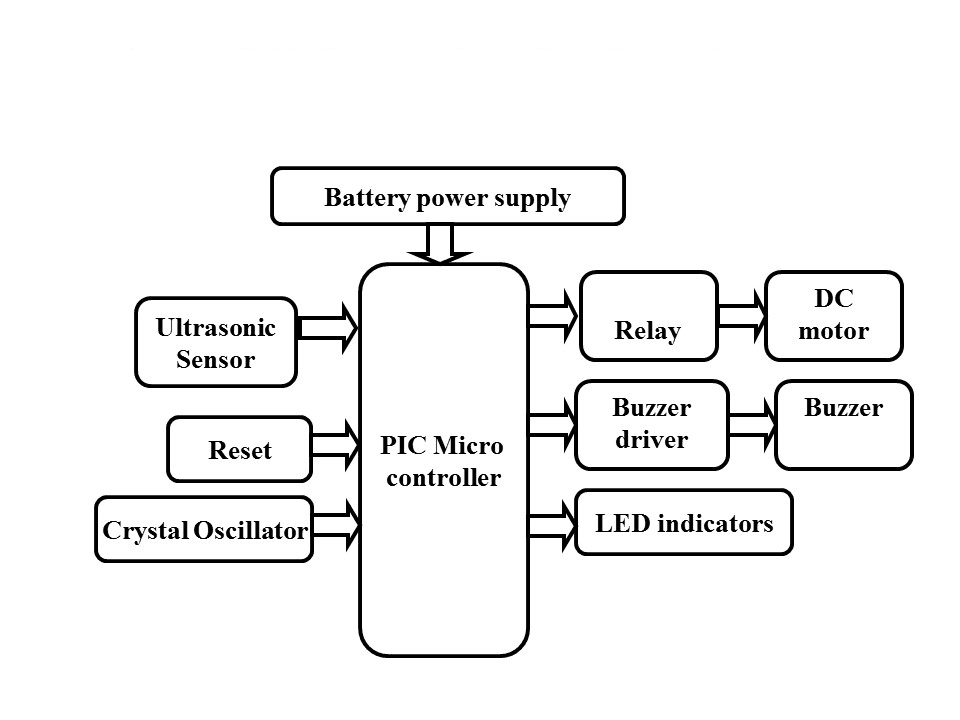
- Automatic braking system.
- Object identification through Ultrasonic sensor.
- Buzzer based alarming system.
- Battery Power Supply.
- PIC Microcontroller.
- Ultrasonic sensor.
- DC motor with Relay driver.
- LED Indicators.
- Buzzer with driver.
- Crystal Oscillator.
- Reset Button.
- LED Indicator.
- PIC-C compiler for Embedded C programming.
- PIC kit 2 programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
 video: