No products in the cart.

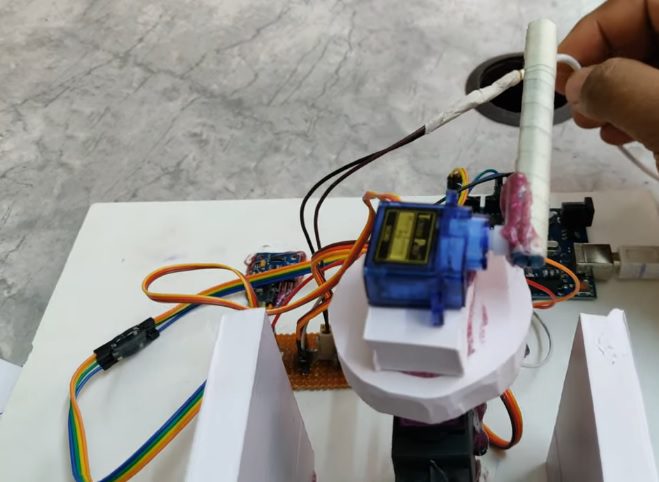
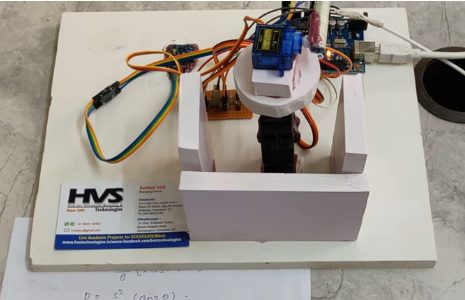
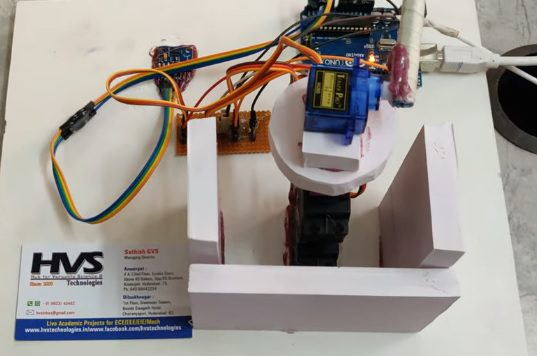
The use of robotic technology essentially very helpful in every area all the more to the field of defense and security are increasingly complex with the growing and development of major appliance defense system more sophisticated to make scientists and students compete to develop robot technology for the purposes of defense and security.
In accordance with the program of Indonesian Army Force (TNI) commander who will always perform modernization and rejuvenation of the main tools of Indonesian defense system, both of Army, Navy and Air Force. From the few examples of defense equipment bought by Indonesia from abroad, such as tanks, warships, military aircraft and so forth, researchers and students are encouraged to make research on technology major appliance defense system especially its gun turret used on military vehicles, the military vehicle itself composed of military ground vehicles, military vehicles sea and air military vehicle that has its own characteristics so the gun turret itself has flexibility because it can be placed on all military vehicles on land, sea or air .It is used for defense and security interests that can be placed in tanks, armored vehicles, warships, and military aircraft.
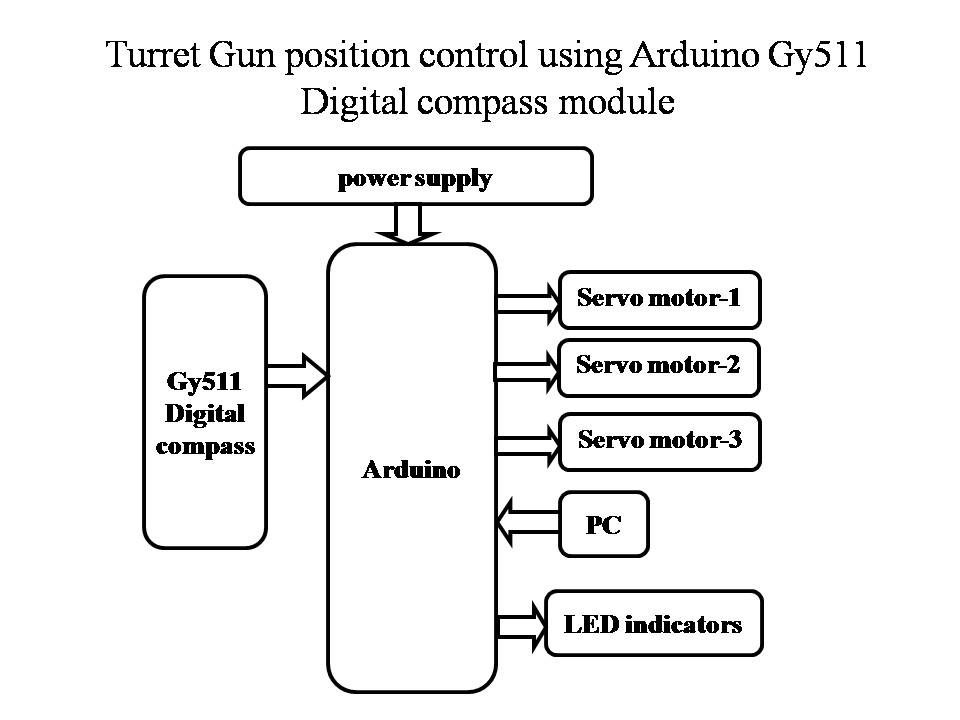
The project aims in designing a gun turret that is able to find the direction of the target and also based on the target direction the gun turret will move using Arduino and GY511digital compass. The ARDUINO Microcontrollers used in the project are programmed using Embedded C language.
The major building blocks of this project are:
 video:
- Arduino Micro Controller.
- Servo motors
- Laptop
- GY511 sensor.
- Embedded C language.
- Arduino IDE studio compiler.
- Express SCH for Circuit design.
 video: