No products in the cart.

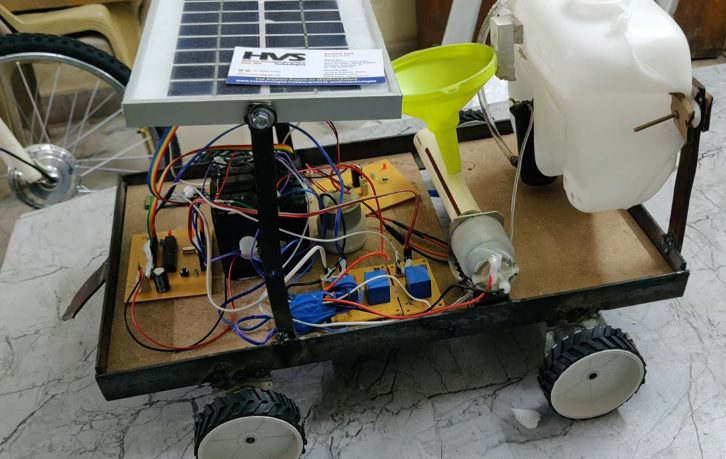
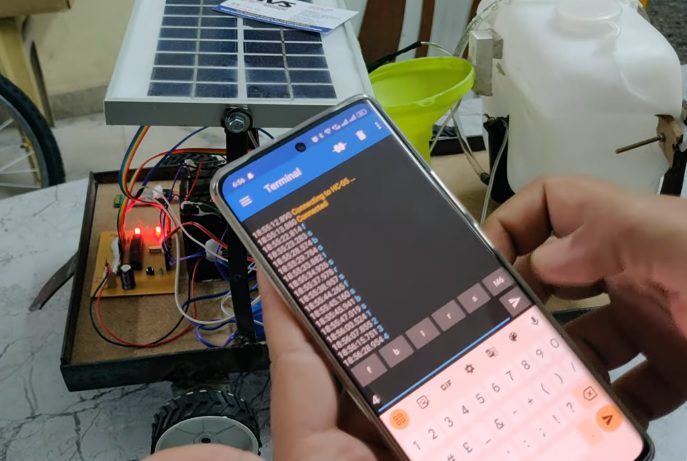
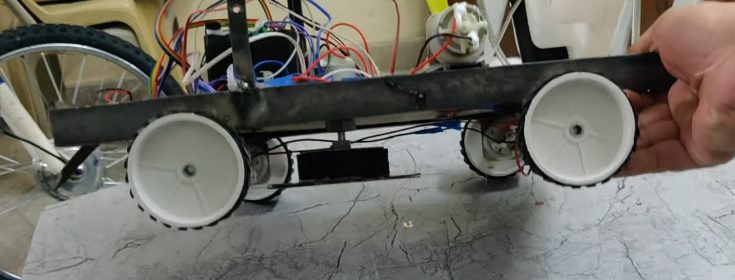
The project “Bluetooth Controlled Multipurpose Agriculture Robot” is designed to perform various agricultural operations such as ploughing, seed sowing, grass cutting, and water spraying using a single robotic system. The robot is controlled wirelessly through an Android mobile phone using an HC-05 Bluetooth module. The user can control the movement of the robot in forward, backward, left, and right directions through commands sent from the mobile application. A microcontroller acts as the main control unit and processes the received commands to control the robot's movement using two DC motors interfaced through a motor driver circuit. For ploughing, a ploughing tool is attached to the front or bottom of the robot, which penetrates the soil as the robot moves forward and prepares the land for seed sowing.
For seed sowing, a rotating motor operates a seed-dispensing pipe containing small holes, while a seed storage funnel supplies seeds into the rotating pipe to distribute them at regular intervals. For water spraying, a DC water pump is controlled through a relay, which supplies water through an attached spraying pipe or nozzle when the ON command is received from the mobile application. Similarly, for grass cutting, a separate DC motor rotates the attached grass-cutting blade, which can be switched ON or OFF through Bluetooth commands. The entire system is programmed using Embedded C, allowing the microcontroller to control the robot's movement and individual agricultural operations independently. Thus, the proposed system reduces manual labour, saves time, and improves agricultural efficiency by integrating multiple farming operations into a single Bluetooth-controlled robotic platform.
The main objectives of the project are:
 video:
- To design and develop a multipurpose agriculture robot capable of performing ploughing, seed sowing, grass cutting, and water spraying operations.
- To control the movement of the robot in forward, backward, left, and right directions using an Android mobile phone through Bluetooth communication.
- To automate the ploughing process by attaching a ploughing tool to the robot.
- To develop an automatic seed-sowing mechanism for uniform seed distribution in the agricultural field.
- To implement a grass-cutting mechanism using a DC motor and cutting blade.
- To automate the water-spraying operation using a DC water pump controlled through a relay.
- To reduce manual labour, save time, and improve the efficiency of agricultural operations.
- To develop a low-cost and user-friendly agricultural robot suitable for small-scale farming.
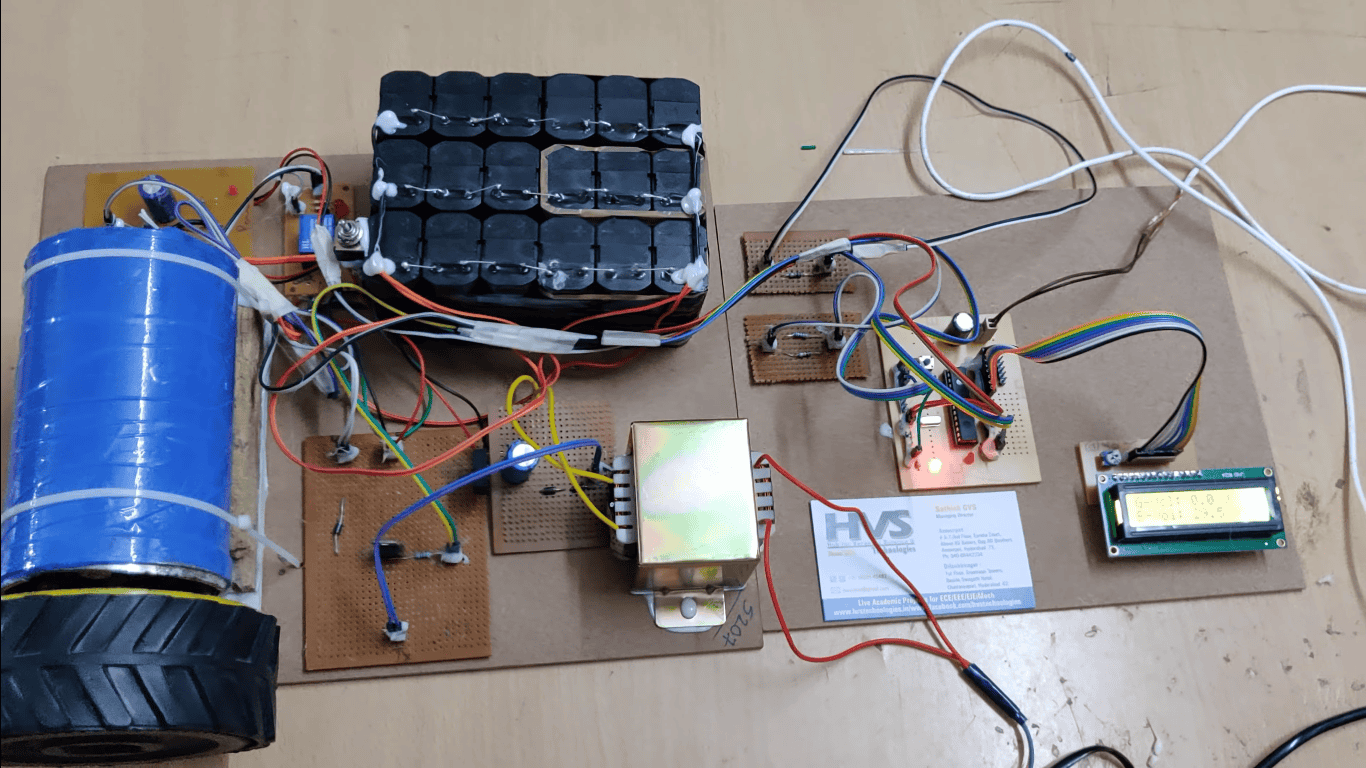
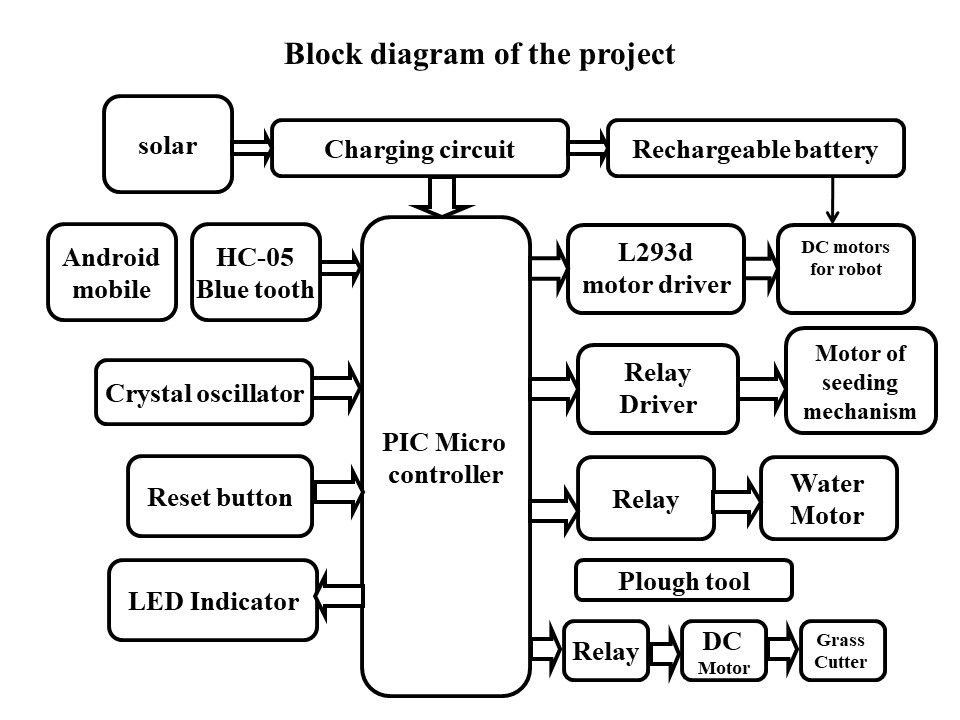
- PIC Microcontroller.
- Solar panel.
- Charging circuit.
- Rechargeable Battery.
- DC Motors Along with L293d Driver.
- HC-05 Bluetooth.
- Crystal Oscillator.
- Reset Button.
- Plough Tool.
- Seed sowing Pipe.
- Water motor.
- Led Indicators.
- Grass cutter.
- Relays.
- PIC-C compiler for Embedded C programming.
- PIC kit 2 programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
- Bluetooth application.
 video: