No products in the cart.

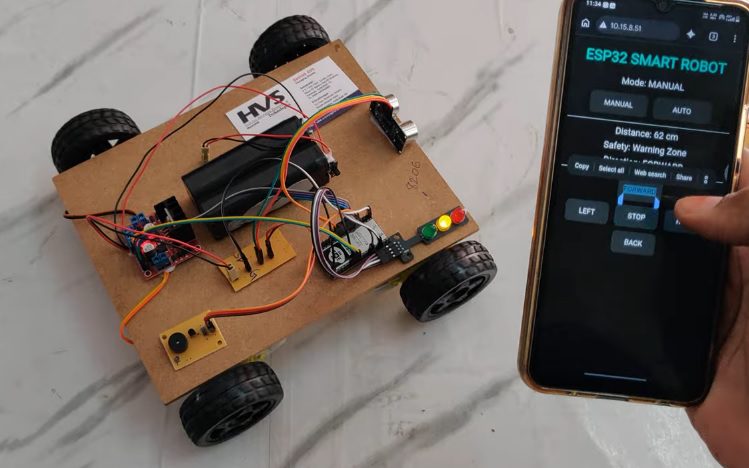
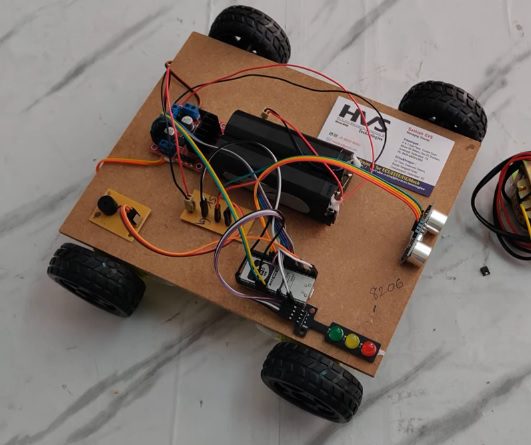
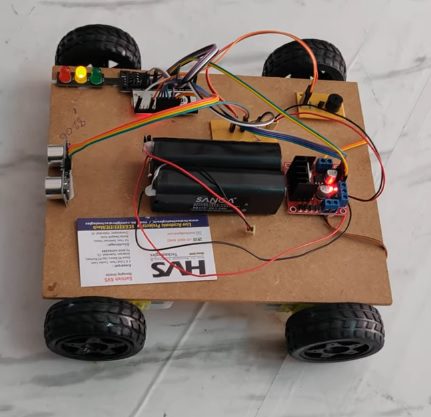
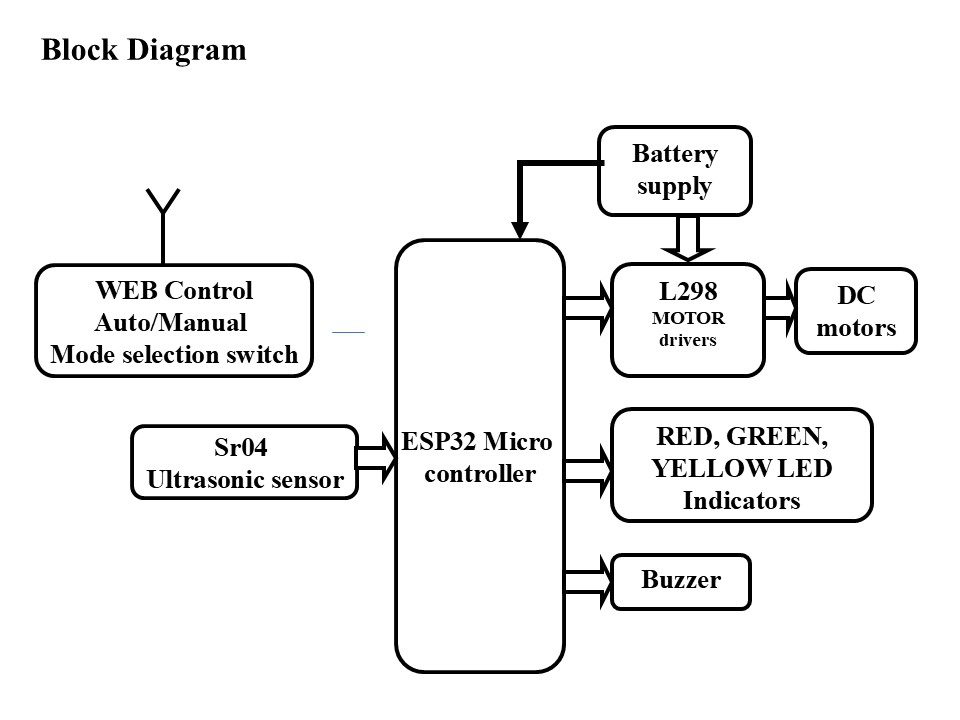
This project presents the design and development of an Automatic Vehicle Collision Prevention System using ESP32 for intelligent vehicle movement, obstacle detection, and collision avoidance. The system consists of an ESP32 microcontroller, HC-SR04 ultrasonic sensor, DC motors, L298 motor driver, red, green, and yellow LEDs, and a buzzer. The vehicle operates in two modes: manual mode and automatic mode. In manual mode, the user controls the vehicle remotely through a web interface, while in automatic mode, the ESP32 continuously measures the distance between the vehicle and nearby obstacles using the ultrasonic sensor. When the obstacle distance is above 100 cm, the green LED turns ON, indicating a safe distance. When an obstacle is detected between 50 cm and 100 cm, the yellow LED turns ON to provide a warning. When the obstacle distance falls below 20 cm, the vehicle automatically stops, the red LED turns ON, and the buzzer sounds continuously to alert the user. The system combines real-time obstacle detection, visual and audible alerts, automatic stopping, and web-based vehicle control to improve safety and provide an effective solution for intelligent robotic and vehicle applications.
Objectives of the project:
 video:
To develop an automatic vehicle collision prevention system using the ESP32 microcontroller.
To detect obstacles in real time using the HC-SR04 ultrasonic sensor.
To provide manual and automatic vehicle control through a web interface.
To turn ON the green LED when the obstacle distance is above 100 cm.
To turn ON the yellow LED when the obstacle distance is between 50 cm and 100 cm.
To automatically stop the vehicle and activate the red LED and continuous buzzer when an obstacle is detected below 20 cm.
To control vehicle movement using DC motors and the L298 motor driver.
To improve vehicle safety through obstacle detection, warning indications, and automatic collision prevention.
The major building blocks of the project are:- Battery power supply.
- ESP32 Microcontroller.
- DC motors with L298 motor drivers.
- Ultrasonic sensor.
- LED indicators.
- Buzzer
- Embedded C programming.
- Arduino IDE programmer for dumping code into Micro controller.
- Express SCH for Circuit design.
- WEB technology.
 video: