No products in the cart.

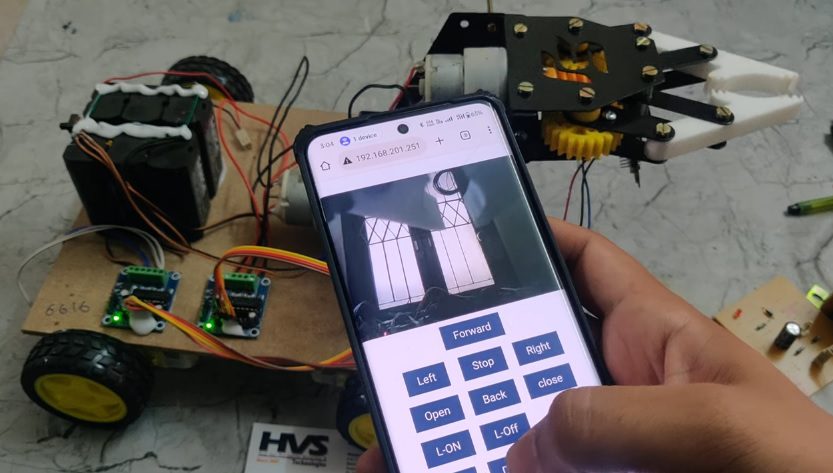
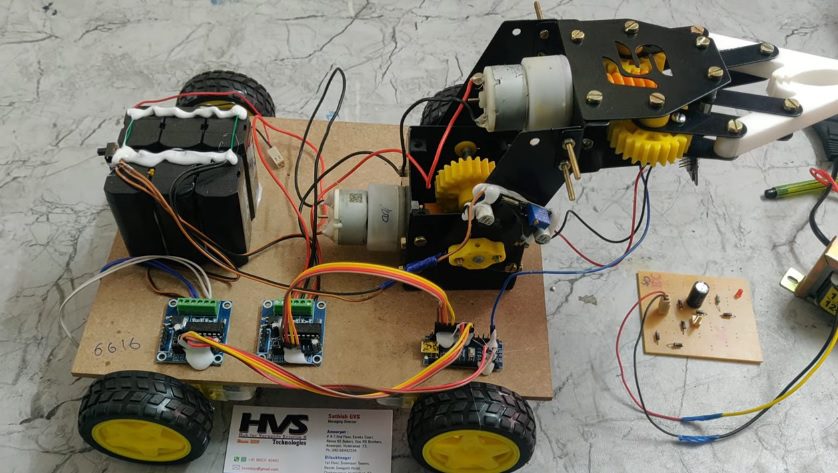
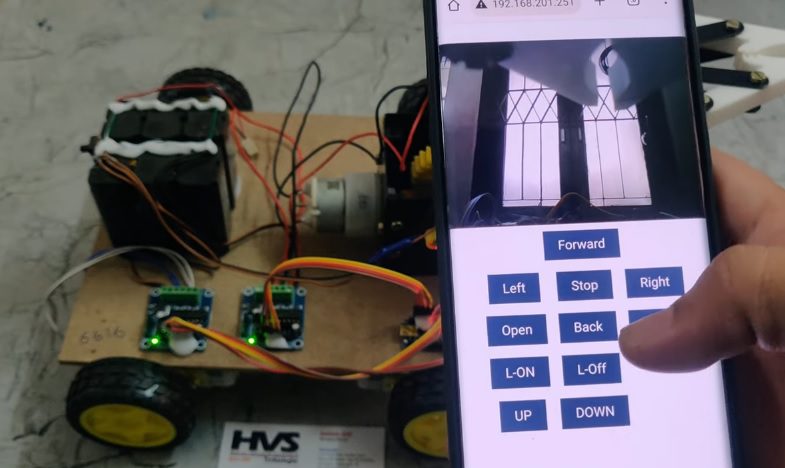
The project aims in designing a touch screen-controlled pick and place robotic ARM which can operated wirelessly through smart phone using IOT technology.
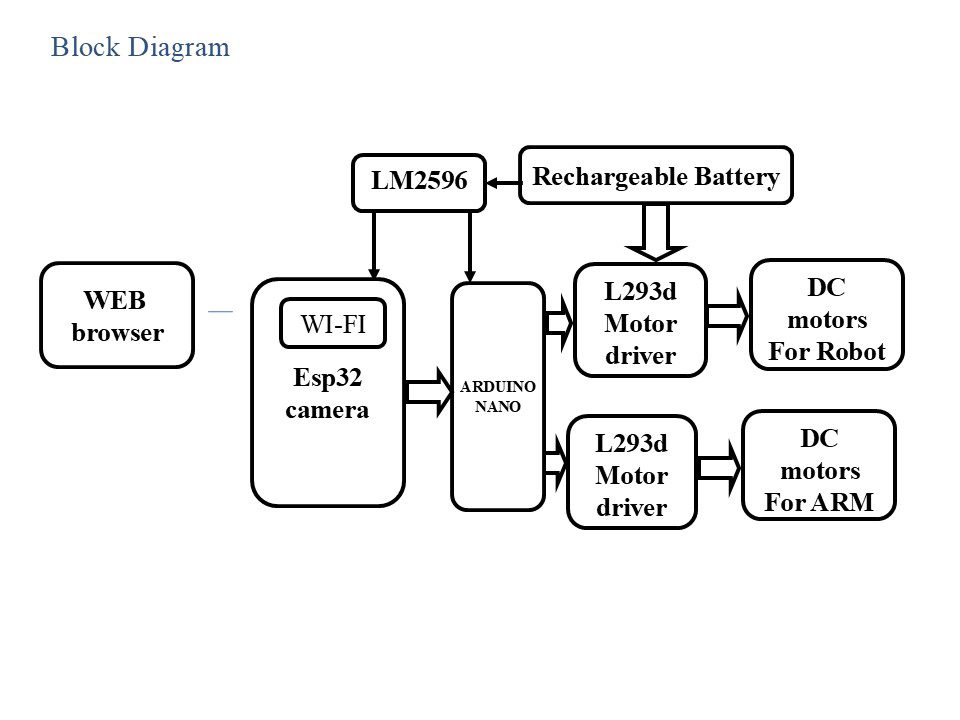
This is the internet of things (IOT) based project, where we are particularly uses the Esp32 camera, robotic ARM, two DC motor along with l293d motor driver. It has an ESP32 camera mounted over it, through which we will get live video feed and the interesting part here is that, we can control the robot-like forward, backward, left and right from a web browser over the internet. The ESP32 cam will capture live data with regards to its surroundings and then send it to a particular IP address through internet. User can access this device using mobile phone and while seeing the video user will control the robotic vehicle along with ARM to pick and place the objects. 12V rechargeable battery is used to provide the power supply to the robot and esp32 camera. The main controlling device of the project is ESP32 camera module which is interfaced with input and output modules. To achieve this task esp32 camera loaded program written in embedded C language.
The objectives of the project include:
 video:
- Design a touch screen-controlled pick and place robotic ARM.
- WEB based surveillance and robot control.
- To achieve this task using ESP32Camera.
- Rechargeable battery.
- ESP32 Camera.
- ARDUINO NANO.
- LM2596.
- DC Motors with L293D driver.
- Robotic ARM.
- Arduino IDE for compiling and dumping code into Microcontroller
- Express SCH for Circuit design.
 video: