No products in the cart.

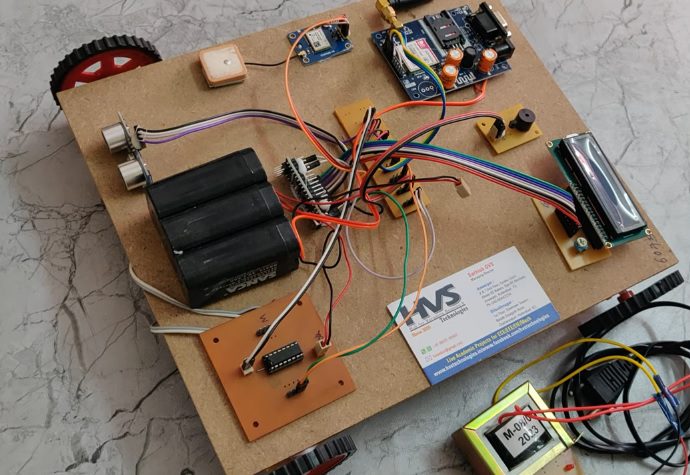
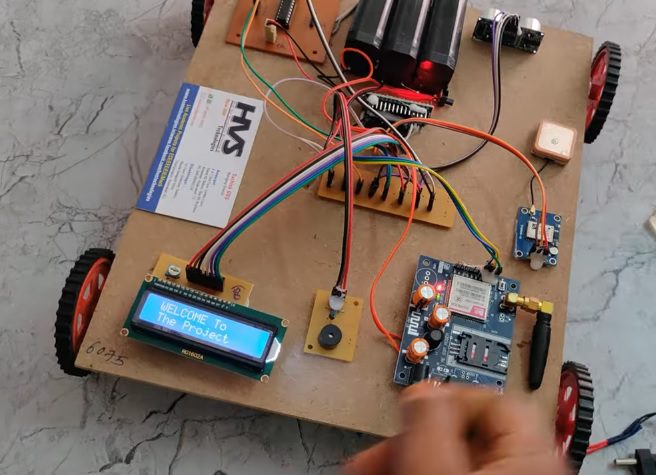
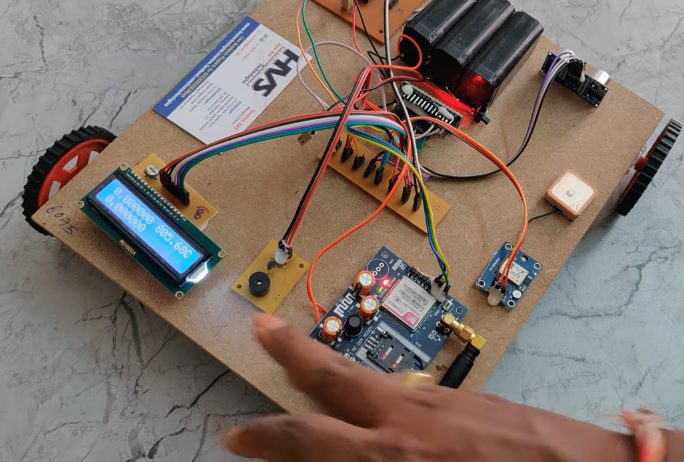
The main aim of this project is to design a vehicle anti-collision and vehicle tracking system. This is a driver-assistance system used to detect the obstacles using sensor and provide the driver with warnings to help avoid a collision. This vehicle consists of GPS technology to track the location of the vehicle. Ultrasonic sensor is used to detect the obstacles and gives the audible alerts through buzzer. GSM module is uses for sending the alert SMS along with location at the specified time.
GPS is the acronym for global positioning system which receives the information from the satellite anywhere in the world and provides the same for controller. The GPS provides us the data like location, time, and speed.
The GSM modem provides the communication mechanism between the user and the microcontroller system by means of SMS messages. It is capable of receiving a set of command instructions in the form of short message service and performs the necessary actions. We will be using a dedicated modem at the receiver module i.e. and send the commands using SMS service as per the required actions.
This project makes use of a micro controller, which is programmed, with the help of embedded C instructions. This Microcontroller is capable of communicating with input and output modules. The controller is interfaced with two DC motors along with l293d motor driver, which are fixed to the vehicle to control the direction of the vehicle. The system also includes obstacle sensors to detect the obstacles in its way and stop the vehicle automatically.
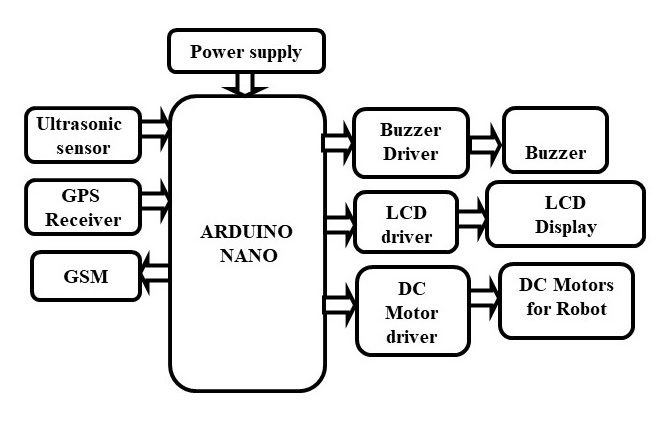
The main controlling device of the project is Arduino Nano Microcontroller. GSM, GPS, LCD display, ultrasonic sensor, Buzzer, DC motors long with L293D motor driver are interfacing to the Arduino nano microcontroller. Ultrasonic sensor is used to detect the obstacle in the path of the vehicle and process this data to the Arduino nano. Then Arduino will activate the buzzer for alerts and stop the vehicle accordingly. Arduino will continuously track the vehicle location from GPS Receiver and sending this location to the predefine mobile number through GSM at the specified time. The status of the project will display on LCD module. This vehicle moves with 12V battery power. To achieve this task microcontroller loaded program written in embedded C language.
The main objectives of the project are:
 video:
- Usage of Arduino nano for achieving the task.
- Obstacle Detection using Ultrasonic sensor.
- Location of Robot can be viewed with the help of GPS.
- GSM based location sending system.
- Battery Power Supply.
- Arduino nano.
- Ultrasonic Sensor.
- GSM module.
- LCD display.
- GPS Receiver.
- DC Motor with L293d driver.
- Buzzer.
- Arduino IDE studio compiler for dumping code into Microcontroller.
- Express SCH for Circuit design.
- Embedded C language.
 video: